
EQUIPMENT
Articulated robots for industrial handling
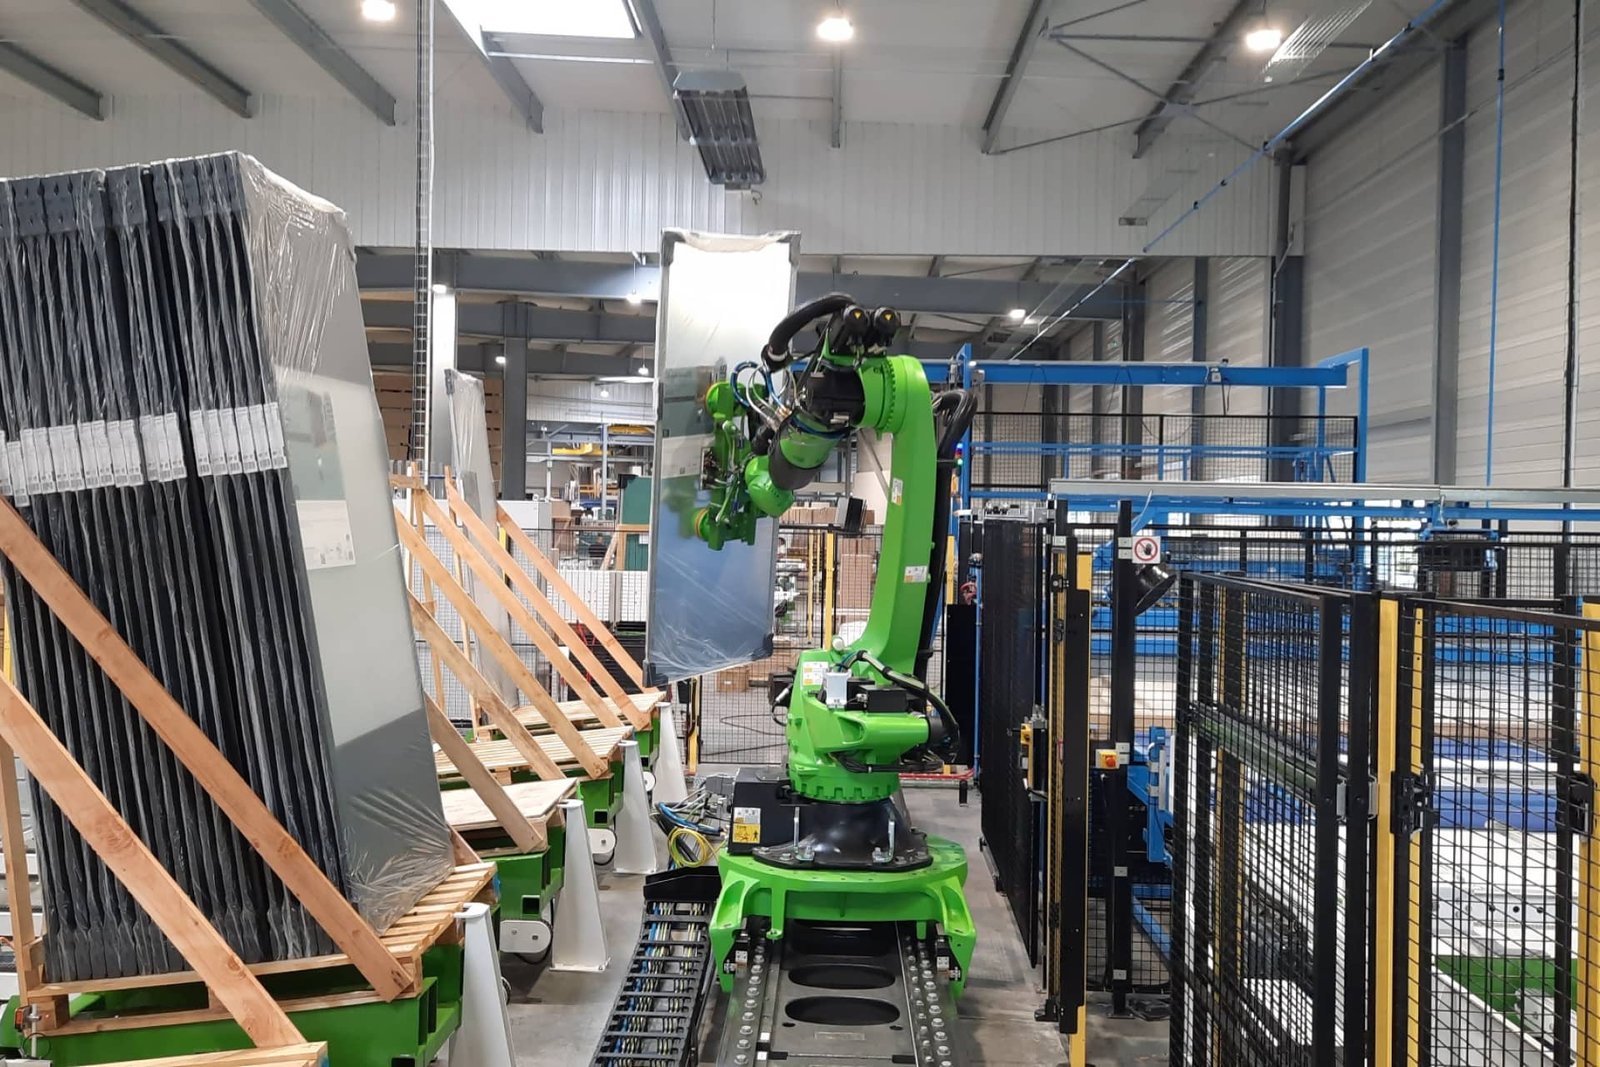
An articulated robot performs handling movements around production stations. With a gripper matched to the product, it feeds stations, retrieves processed products and palletises loads, including heavy products.
Architecture
Multi-axis robot
Applications
Station feeding, product retrieval and palletizing
Gripping
Custom tools with functions adapted to the product
Integration
Robotic cell or production line
Loads
Heavy-product handling, depending on the selected robot and gripper
How it works
The robot moves the product with a gripping tool designed for its permitted contact areas and the operations required. A multifunction gripper can combine several tasks within the same cycle.
FIMEC SH integrates the robot into a robotic handling cell, taking account of the stations served, access and the line environment.
Key features
Adaptation
Possible reassignment following assessment of a process change
The sources describe a multifunction cell handling concrete products around a finishing unit. Its functions include:
- depalletising boards and feeding the finishing station;
- collecting products after processing;
- removing empty boards;
- changing pallets;
- palletising and placing wooden spacers.
The robot and gripper are selected for the functions included in the application. This example shows their role within a complete production sequence.
A tool matched to the load
Product shape, weight and permitted contact areas guide tool design. Gripping, holding and placement functions are considered together.
Reassignment of an existing robot
A process change may allow a robot to be reassigned. This possibility is assessed against the new operations, gripper and line environment. The configuration is checked for the handling task concerned.